
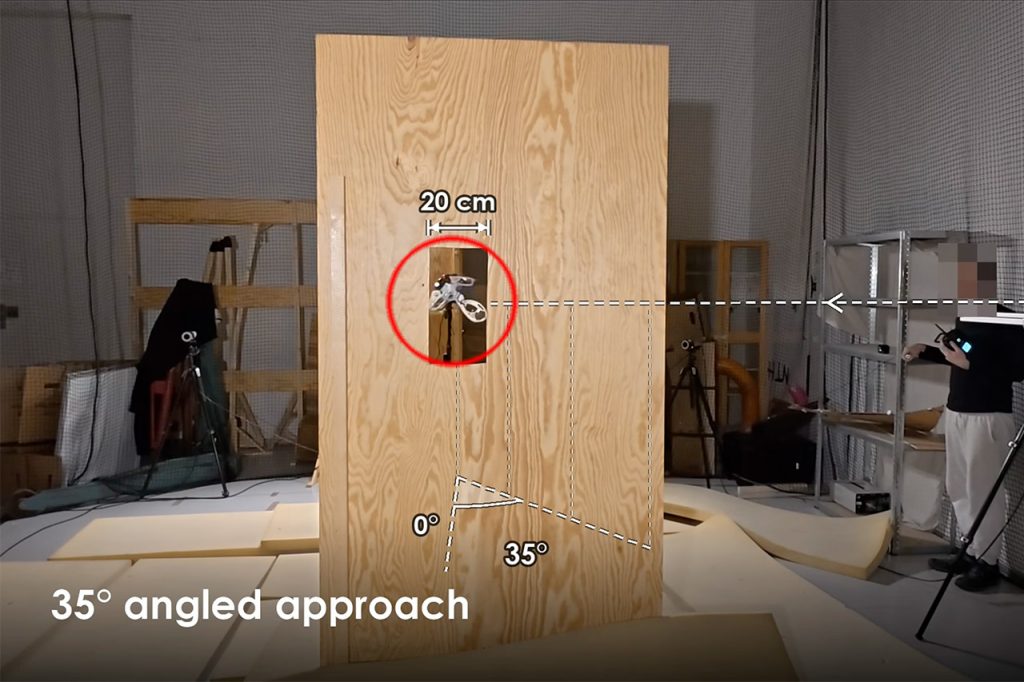
Researchers at the Autonomous Robots Lab at the Norwegian University of Science and Technology, working with colleagues from ETH Zurich and the University of Bonn, set out to solve a stubborn problem for small flying robots. Cluttered indoor spaces, tunnels, and inspection sites often contain openings smaller than a quadrotor’s normal width. Rigid frames force […]